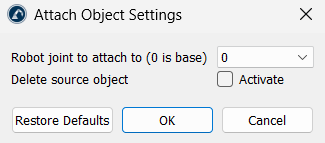
Attach Object to Robot Link
This utility permanently locks an object onto a specific moving joint or link of a robot arm. The selected object becomes a permanent part of the robot arm and moves along with that specific joint during simulation. You can choose any moving link, from the base (Joint 0) up to the mounting plate at the end of the arm.
Note: The object geometry is merged into the robot link, so this cannot be undone from the Add-in. Enable Delete source object (the Activate checkbox next to it) to remove the original object from the station tree once it has been merged.