Enable Simulated Probing
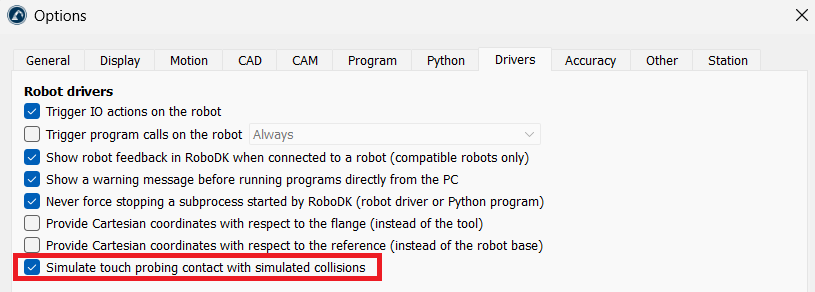
To test the routine without a real probe, let RoboDK simulate the trigger. Select Tools ➔ Options ➔ Drivers, select Simulate touch probing contact with simulated collisions and click OK. The search moves then stop on the simulated contact between the probe and the part; the Add-in enables that collision pair for you when it generates the program.