



9 hours ago
I find it hard to understand how to create mechanisms in robodk, i followed the course about that in youtube but i still don't figure it out how does this work.
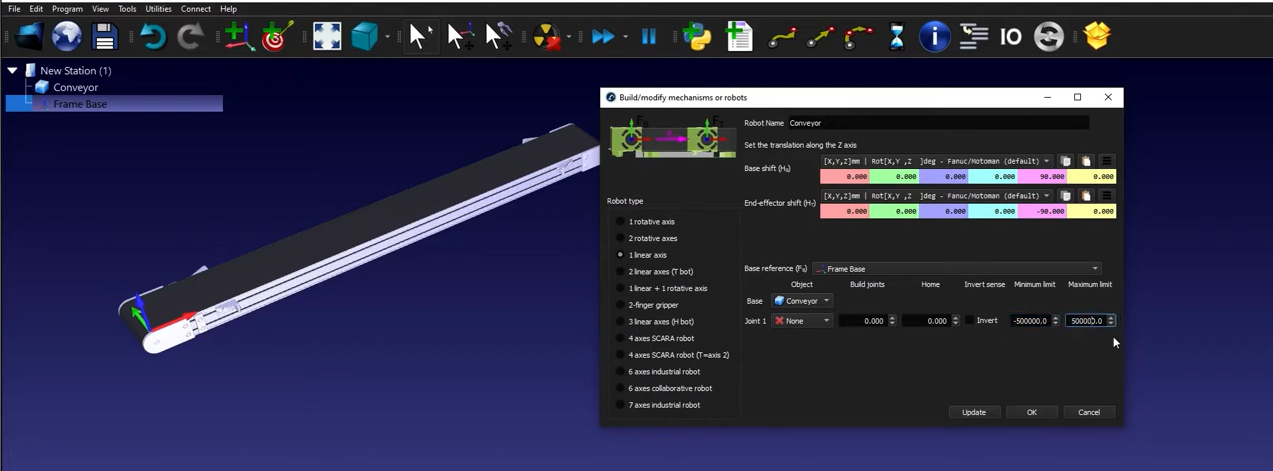
For example if we create a linear axis : the base shift do a transformation and translation to the base, and end effector shift do a transformation and translation to the resul'ts base
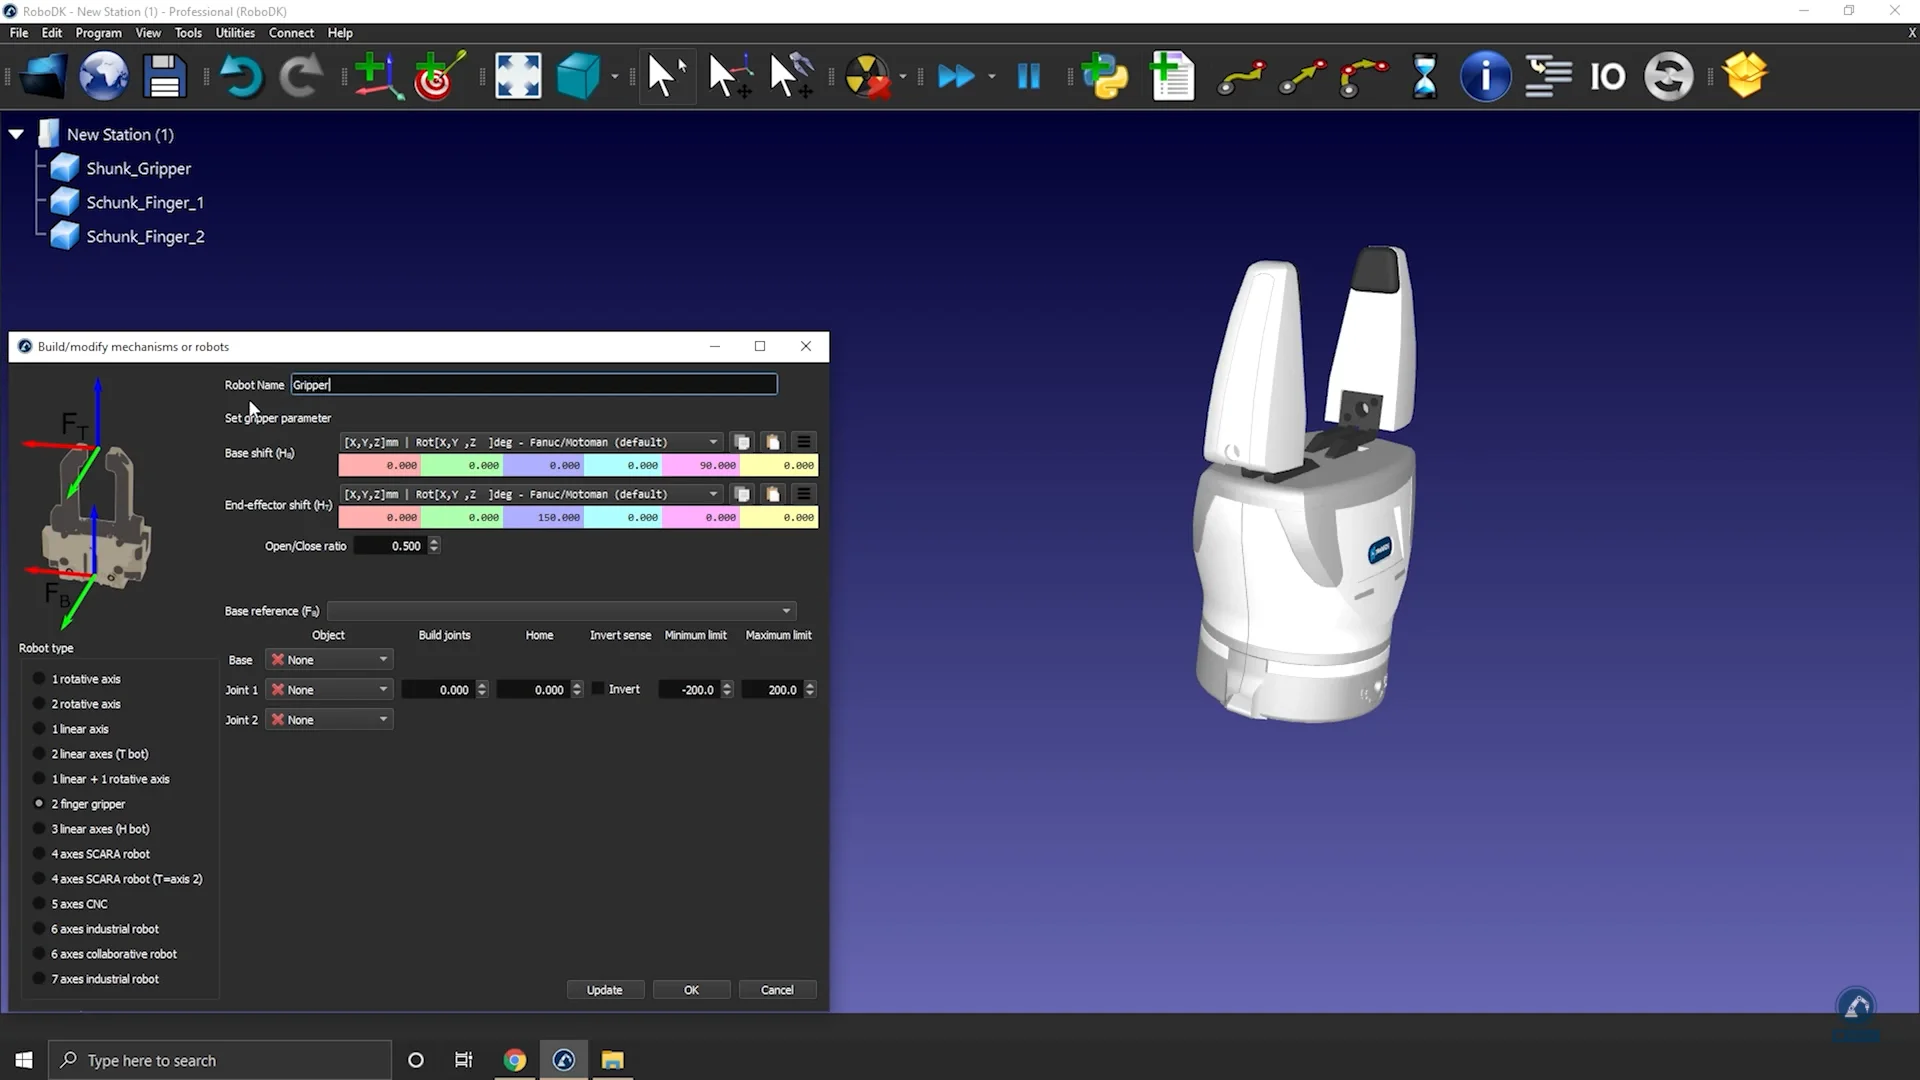
But i don't think that the same thing is happening when we try create a gripper, like event that we supposde to have the same settings, but there is no change in the orientation
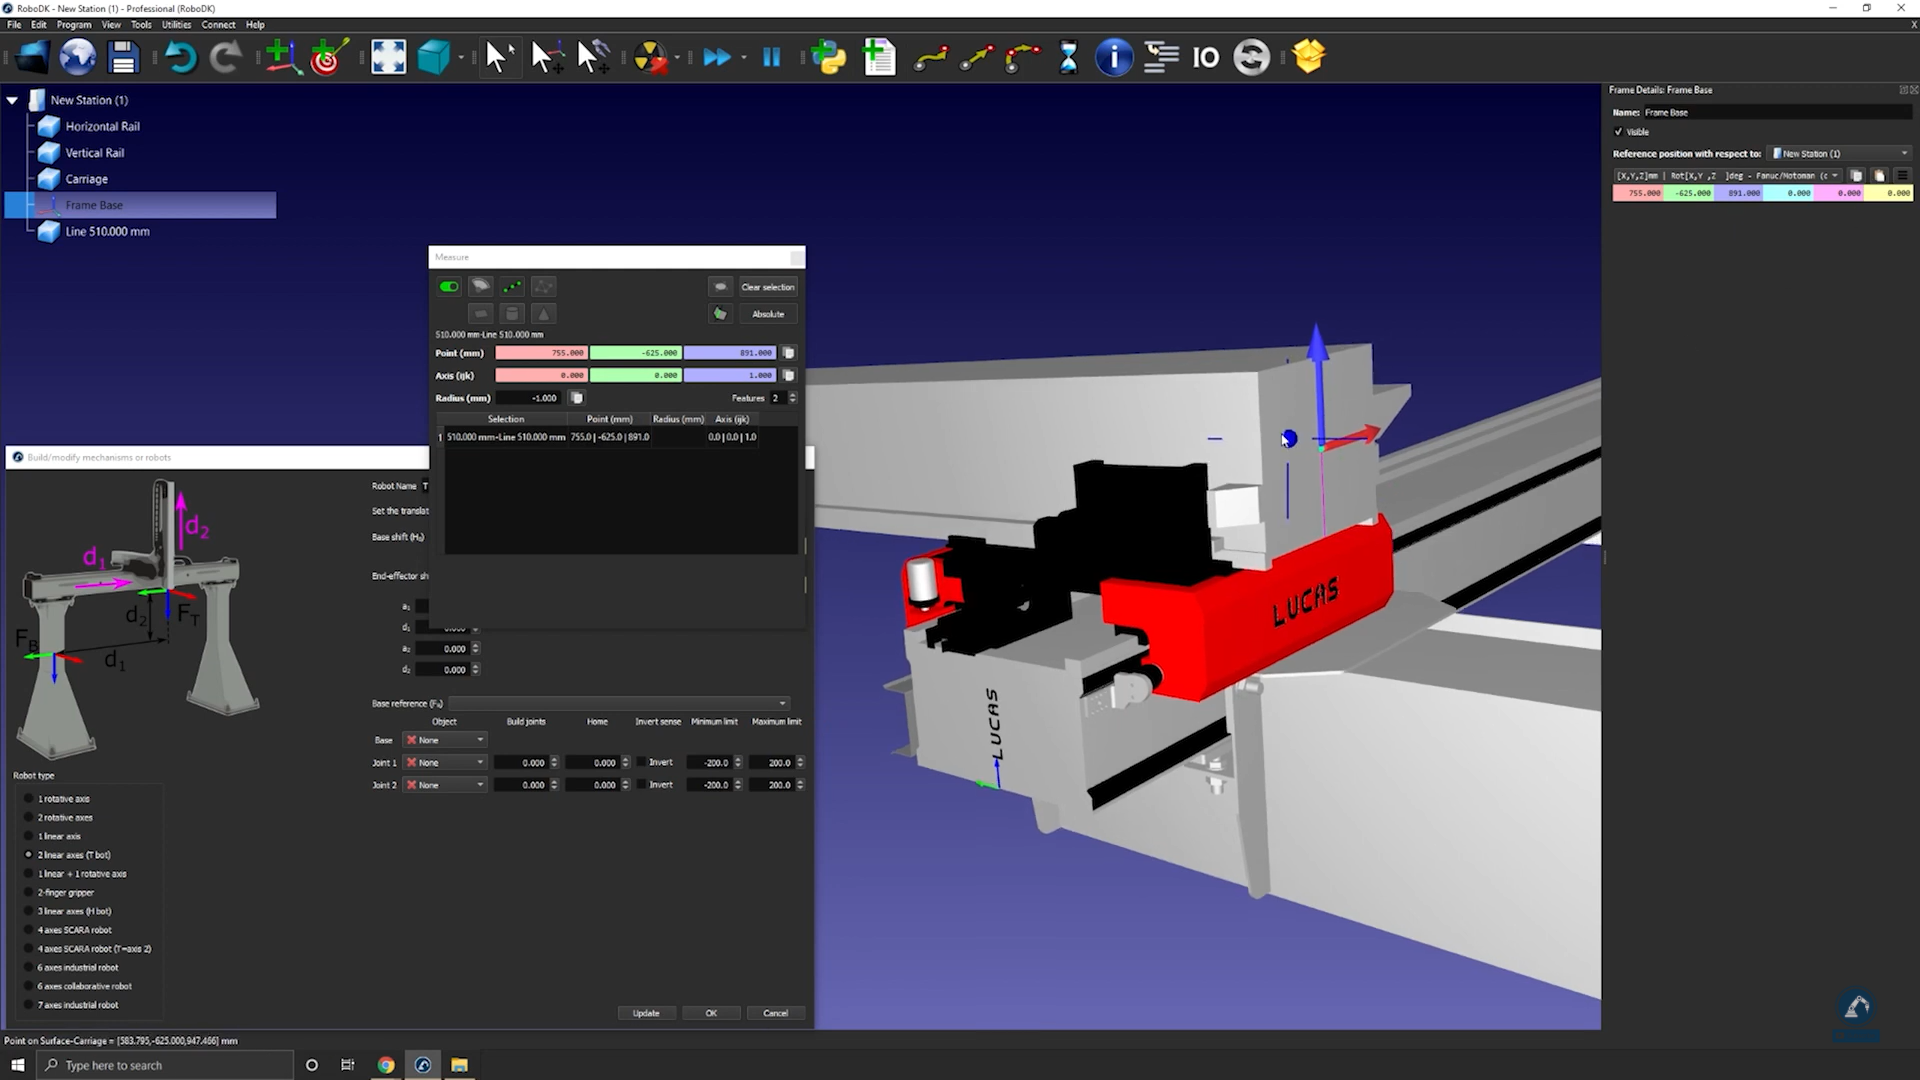
Also in this example, i can't understand where i should put my base frame, and i don't how it's orientation affect the translation along x and y, abd what is the difference between Fb and Ft, and why in the video the instructor positioned the base reference in Ft, and what does d1 and d2 mean and the same for d1,d2 and a1,a2
I didn't find answers to all of this in the youtube videos nor in the documentation so can please anyone from the robodk team explain me more about how create mechanisms, and explain me where to put the refrence fram, how i should orientate it, the base shift and end effector, and how to know where is the direction of the movement. And also if possible how can i understand all of this from the image that appears when we open the tab that let us create the mechanism
For example if we create a linear axis : the base shift do a transformation and translation to the base, and end effector shift do a transformation and translation to the resul'ts base
But i don't think that the same thing is happening when we try create a gripper, like event that we supposde to have the same settings, but there is no change in the orientation
Also in this example, i can't understand where i should put my base frame, and i don't how it's orientation affect the translation along x and y, abd what is the difference between Fb and Ft, and why in the video the instructor positioned the base reference in Ft, and what does d1 and d2 mean and the same for d1,d2 and a1,a2
I didn't find answers to all of this in the youtube videos nor in the documentation so can please anyone from the robodk team explain me more about how create mechanisms, and explain me where to put the refrence fram, how i should orientate it, the base shift and end effector, and how to know where is the direction of the movement. And also if possible how can i understand all of this from the image that appears when we open the tab that let us create the mechanism